Research
I study how to design complex systems that people can operate safely, mostly in human spaceflight, using controlled experiments, analog mission studies, and mathematical models.
Crew Autonomy and Self-Scheduling
On a Mars mission, messages between the crew and Earth can take up to 22 minutes each way. Mission Control can't help in real time, so crews will need to manage their own timelines and handle problems as they come up.
I develop and test self-scheduling tools that let crews plan and revise their own activities. The main question is how to design these tools so that astronauts, who aren't expert planners, can manage complex timelines and adapt when plans change.
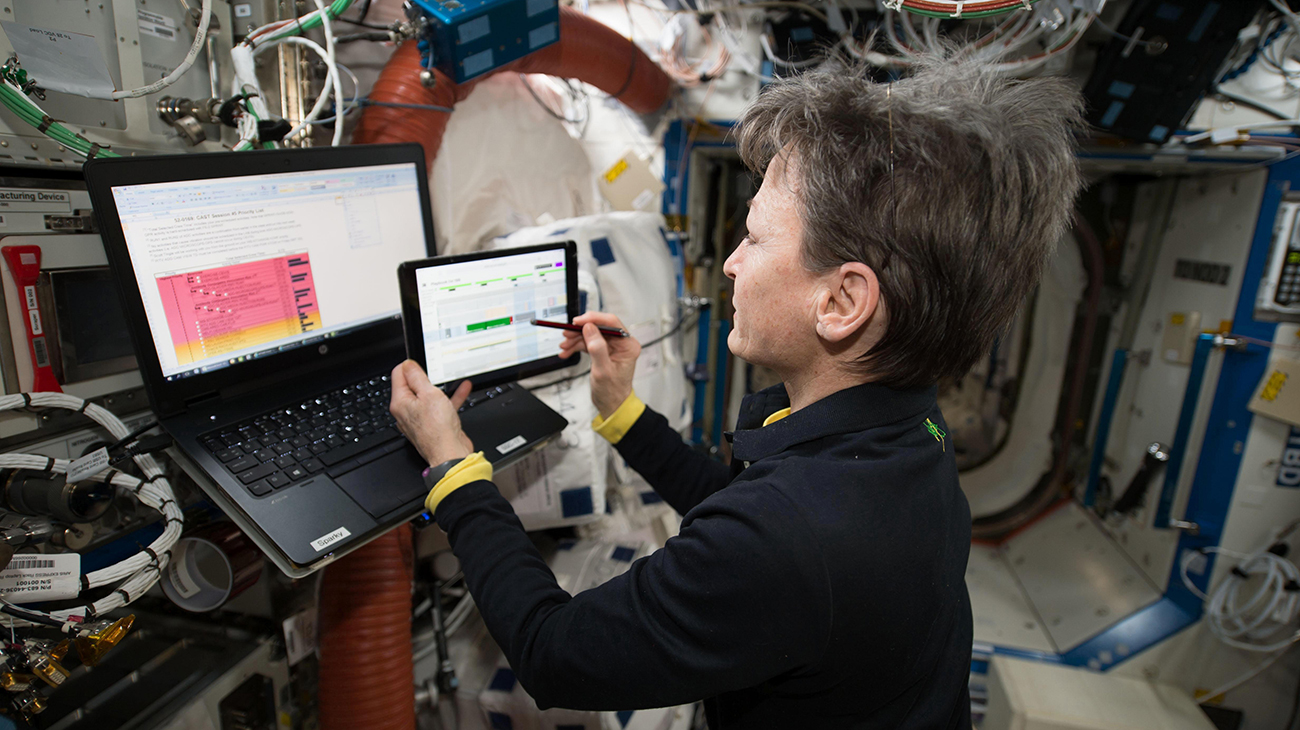
I've tested scheduling interfaces in NASA's Human Exploration Research Analog (HERA) and aboard the International Space Station (ISS), and identified design factors that help crews schedule on their own. I also help develop Playbook, NASA's planning software. Playbook is used in analog missions, including HERA and the Crew Health and Performance Exploration Analog (CHAPEA), and in lunar payload deliveries through the Commercial Lunar Payload Services (CLPS) program. These results inform software design for the Artemis missions.
Related Publications
Human-Automation and Robotic Interaction
Deep-space crews will rely heavily on automation and robots. Decisions about crew size and automation are made early in mission design and shape spacecraft architecture and life support requirements. This research helps mission planners weigh the risks and benefits of new automation and robotic technologies before those decisions are fixed.
I develop trade-space analyses that use human performance models to show how crew size, automation, and mission parameters affect each other. These analyses found that a crew of four, the baseline for Mars missions, may not have enough expertise to handle unexpected failures across critical systems, and that keeping workload at current ISS levels would take a larger crew in deep space.
The research has also produced design guidelines for human-automation interaction in space operations. They cover appropriate trust, supervisory control over communication delays, and situational awareness while automation runs complex tasks. To support human-in-the-loop studies, I've built simulations for measuring operator performance across different configurations.
Related Publications
Augmented Feedback and Performance Modeling
My doctoral research asked whether automated feedback can help people learn and retain complex manual control skills faster, the way an expert instructor does.
I showed that concurrent bandwidth feedback, real-time guidance that turns on only when an operator's error exceeds a threshold, improves performance and shortens training without increasing cognitive workload. Like a good instructor, it steps in only when needed, so trainees get support without coming to depend on it.
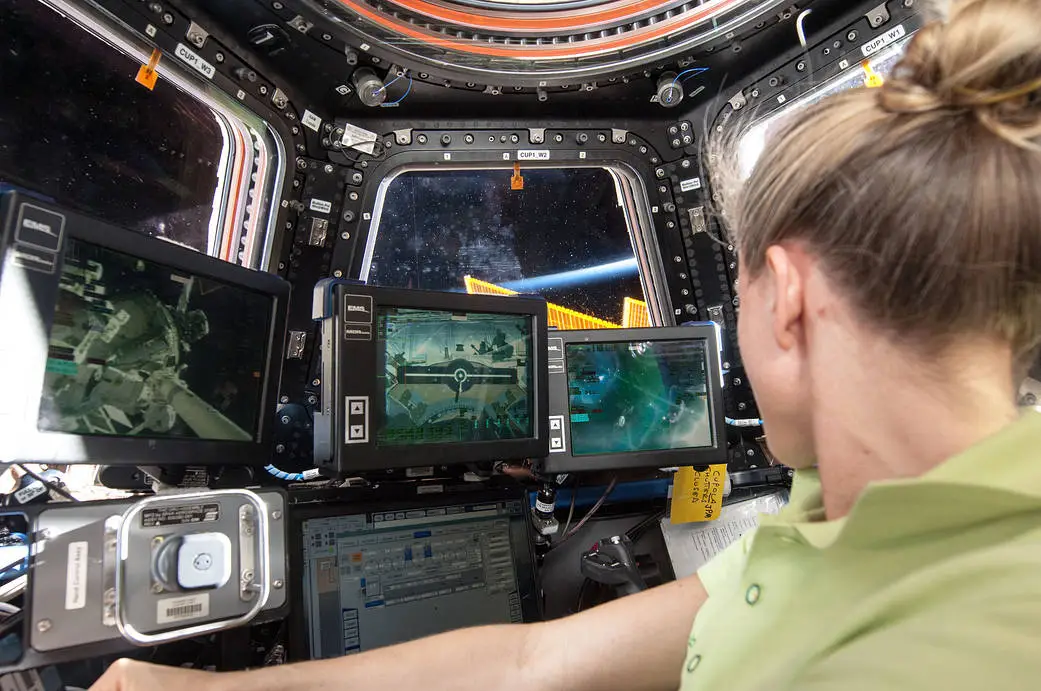
Training astronauts for manual control tasks like spacecraft docking takes a lot of time and money. The same approach could shorten training for surgery, piloting, and other skilled manual tasks.
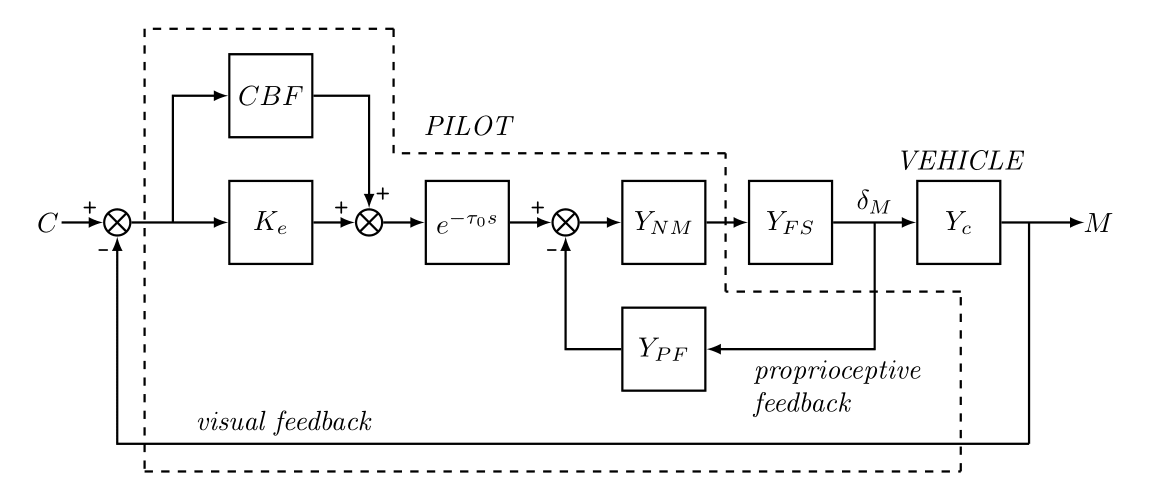
I also extended Hess's Structural Model of the human pilot, a model of pilot perception and control behavior, to predict the effects of concurrent bandwidth feedback. The extended model can be used to tune feedback parameters and predict training outcomes. I validated it with simulators I built for real-time performance assessment.